Key takeaways
- has designated Red Hat Enterprise Linux (RHEL) as an official Tier-1 supported platform.
- Tier-1 status guarantees continuous integration, nightly build verification, binary packaging, and release-blocking bug resolution for RHEL environments.
- The integration equips physical AI and industrial robotics teams with enterprise lifecycle stability, hardware accelerator driver validation, and hardened security controls.
- Community coordination and package maintenance continue through the upstream Fedora Robotics Special Interest Group.
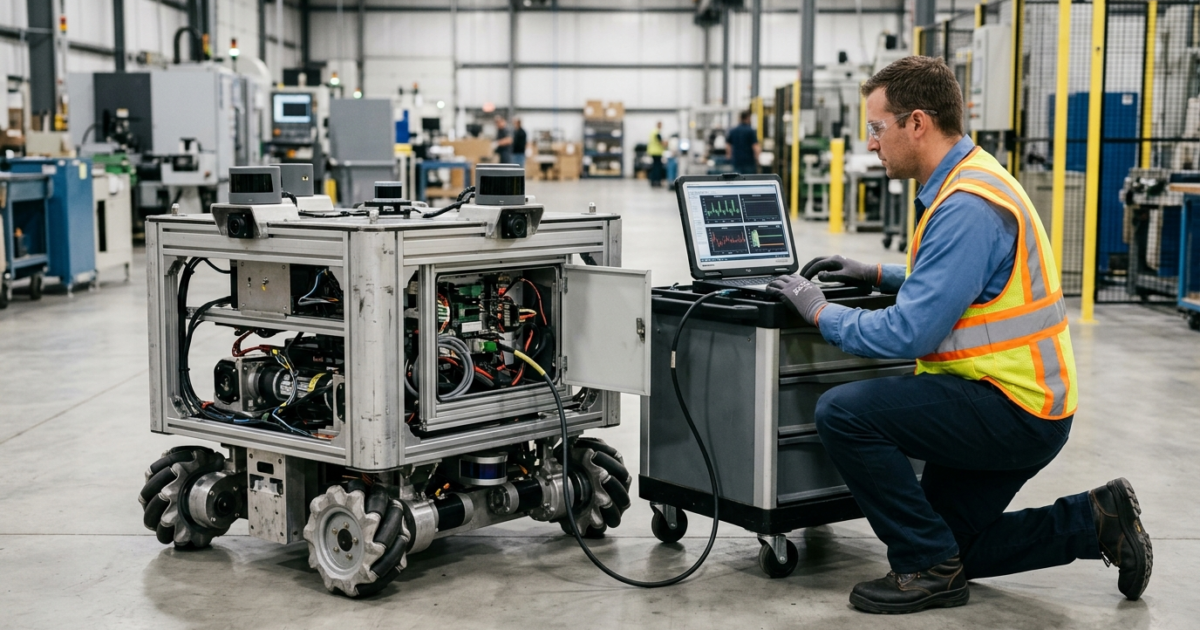
The Robot Operating System (ROS 2) has officially designated Red Hat Enterprise Linux (RHEL) as a Tier-1 supported platform, establishing enterprise Linux as an authoritative operating environment for industrial robotics and physical AI. Under this designation, RHEL workloads receive continuous integration, nightly automated builds, binary packaging, and prioritized bug remediation that directly guards release stability. Previously maintained under Tier-2 support for releases such as Jazzy Jalisco, RHEL joins Ubuntu as a primary foundation for robotics developers. For enterprise technology leaders, this shift links experimental robotics development with enterprise-grade security controls, certified accelerator drivers, and predictable operational lifecycles required for scaling autonomous systems across production facilities.
RHEL Elevated to Tier-1 Support in ROS 2
In the robotics ecosystem, platform tiering governs engineering reliability. According to ROS Enhancement Proposal 2000 (REP 2000), which defines target platforms and testing commitments across ROS 2 releases, support tiers indicate how rigorously an operating system is maintained by core project developers.
Historically, core ROS 2 development centered predominantly on Ubuntu LTS distributions as the primary Linux Tier-1 target. While effective for academic research and rapid software prototyping, this pattern created operational hurdles for enterprise organizations whose IT and operational technology (OT) policies require Red Hat infrastructure. In previous releases, RHEL 9 was tracked as a Tier-2 platform, meaning packaging and automated builds occurred periodically on a best-effort basis, and unresolved bugs did not hold back scheduled release dates.
Elevation to Tier-1 status formally integrates RHEL into the main continuous integration (CI) pipeline of ROS 2. Critical defects identified on RHEL are treated as high-priority issues that can pause release candidates, ensuring that organizations deploying ROS 2 nodes on enterprise hardware do not encounter unexpected breakages when upgrading distributions.
Engineering Rigor and Enterprise Lifecycle Guarantees
Deploying robotics software in live factory floors, logistics centers, and energy infrastructure requires operational discipline that standard community repositories rarely satisfy. Moving RHEL to Tier-1 status provides technical teams with three distinct architectural advantages:
| Support Level | Testing Cadence | Packaging and CI | Bug Resolution Priority | Release Impact |
|---|---|---|---|---|
| Tier 1 | Nightly builds and automated CI pipelines | Pre-built binary packages with regular integration testing | High priority; core maintainer triage | Release-blocking for critical defects |
| Tier 2 | Periodic automated testing | Buildable source archives; periodic packaging | Best-effort triage subject to available resources | Non-blocking for scheduled releases |
| Tier 3 | Community-driven testing only | Source-only builds without official validation | Dependent entirely on community patches | No release dependency |
First, enterprise robotics requires long-term lifecycle predictability. Industrial automation equipment operates on five-to-ten-year deployment horizons. Frequent operating system migrations introduce regression risks into safety-critical kinematics and sensor drivers. RHEL delivers prolonged stability windows, backported security fixes, and rigid application binary interface (ABI) consistency, permitting robotics platform teams to maintain stable software stacks without being forced into frequent base-OS rebuilds.
Second, physical computing workloads rely heavily on hardware acceleration. Autonomous mobile robots (AMRs), automated guided vehicles (AGVs), and spatial perception systems require tight coordination between kernels, GPUs, neural processing units (NPUs), and real-time network buses. RHEL provides a validated driver ecosystem that standardizes accelerator integration, allowing developers to target edge silicon without maintaining bespoke driver patches across machine fleets.
Third, enterprise compliance standards require continuous security governance from kernel to edge container runtimes. Implementing SELinux policies, cryptographic integrity checks, and centralized telemetry on mobile machines is essential when robots interact with internal corporate networks. Teams standardizing edge computing infrastructure can build on established organizational patterns for streamlining container security, ensuring that ROS 2 microservices running in edge pods adhere to certified supply chain baselines.
Operational Impact on Industrial Fleets and Physical AI
The convergence of generative AI models and physical machinery—often categorized as physical AI—presents infrastructure demands that exceed traditional web or cloud applications. Autonomous machines process multi-modal sensor inputs, compute navigation trajectories, and issue motor commands within millisecond boundaries. Any kernel panic, driver timeout, or communication deadlock carries direct physical and financial consequences.
Bridging RHEL with ROS 2 establishes an open foundation that limits vendor lock-in. Historically, industrial teams seeking deterministic behavior turned to proprietary, closed-source operating stacks. Tier-1 RHEL support enables engineering organizations to build modular architectures, test reinforcement learning algorithms within digital twin simulation environments, and transition workloads directly from virtual testing pipelines onto physical hardware using identical Linux system libraries.
Furthermore, this integration removes a chronic organizational friction between software developers and enterprise IT administrators. Robotics engineers have frequently built pilots on community Linux builds that enterprise security officers could not approve for production networks. With RHEL recognized as a first-tier ROS 2 platform, robotics programs gain an approved runway for procurement, compliance auditing, and operational scale.
What happens next
Upstream development for Red Hat’s robotics tooling continues through the Fedora Robotics Special Interest Group (SIG). The working group manages the native RPM packaging, containerized deployment recipes, and testing infrastructure in Fedora that directly seed enterprise RHEL capabilities.
Engineering leaders evaluating robotics infrastructure should take the following steps:
- Review active ROS 2 distribution roadmaps within REP 2000 to identify when specific packages transition into Tier-1 automated build pipelines for RHEL.
- Audit existing custom ROS 2 packages and C++ or Python nodes against RHEL-supported compiler versions and toolchains.
- Verify peripheral device drivers and hardware acceleration modules against enterprise Linux kernel compatibility lists before scaling hardware procurement.
As automated testing matrices expand across both x86_64 and ARM64 architectures, enterprise infrastructure teams can expect expanded packaging repositories and containerized blueprints that simplify rolling out production fleets across industrial facilities.
Sources: Red Hat Announcement, ROS Enhancement Proposal 2000 (REP 2000), Fedora Robotics Special Interest Group.


